Honours Mechatronics Engineering student with the AI option at the University of Waterloo. I have hands-on experience in robot control, vision, and perception, and I'm especially interested in modelling systems and turning those models into software that runs on real hardware.
Red Rabbit Robotics
Core software for a robot built from scratch: actuator control libraries, vision and calibration, teleoperation, and Bayesian-optimized PID tuning. The robot was demoed to customers across the U.S.
Jan 2026 – Aug 2026
Burnaby, BC
Active & Interactive Robotics Lab, University of Waterloo
Explored methods for implementing impedance control on PAL Robotics' TIAGo Pro.
Sep 2025 – Dec 2025
Waterloo, ON
Robotic Interaction, Perception and Learning Lab, University of Waterloo
Factor-graph (GTSAM) estimation of how articulated and flexible objects move, plus joint and Cartesian impedance control with time-optimal trajectory tracking on a Franka Emika Panda.
May 2025 – Aug 2025
Waterloo, ON
Waterloo Aerial Robotics Group
Created the PCB layout for an STM32-based CAN-to-UART adapter that bridges sensor data onto the drone's CAN bus, and assembled PCBs with reflow soldering and wire harnessing for a small airplane.
Feb 2025 – Aug 2025
Waterloo, ON
Ford Motor Company
Embedded cryptography improvements: resolved 1000+ code issues and added unit tests with Google Test.
Sep 2024 – Dec 2024
Kanata, ON
BlackBerry QNX
Automated and manual testing on Qualcomm, Bosch, and NXP ECUs running QNX and Android Automotive, supporting proof-of-concept demos for OEMs like Nissan and Ford.
Jan 2024 – Apr 2024
Kanata, ON
Audesse Automotive
Built an algorithm that decodes multiplexed CAN bus data using DBC files, which became a new product for customers, plus a full-stack page with AWS DynamoDB for creating custom ECU configuration files.
May 2023 – Aug 2023
Kitchener, ON

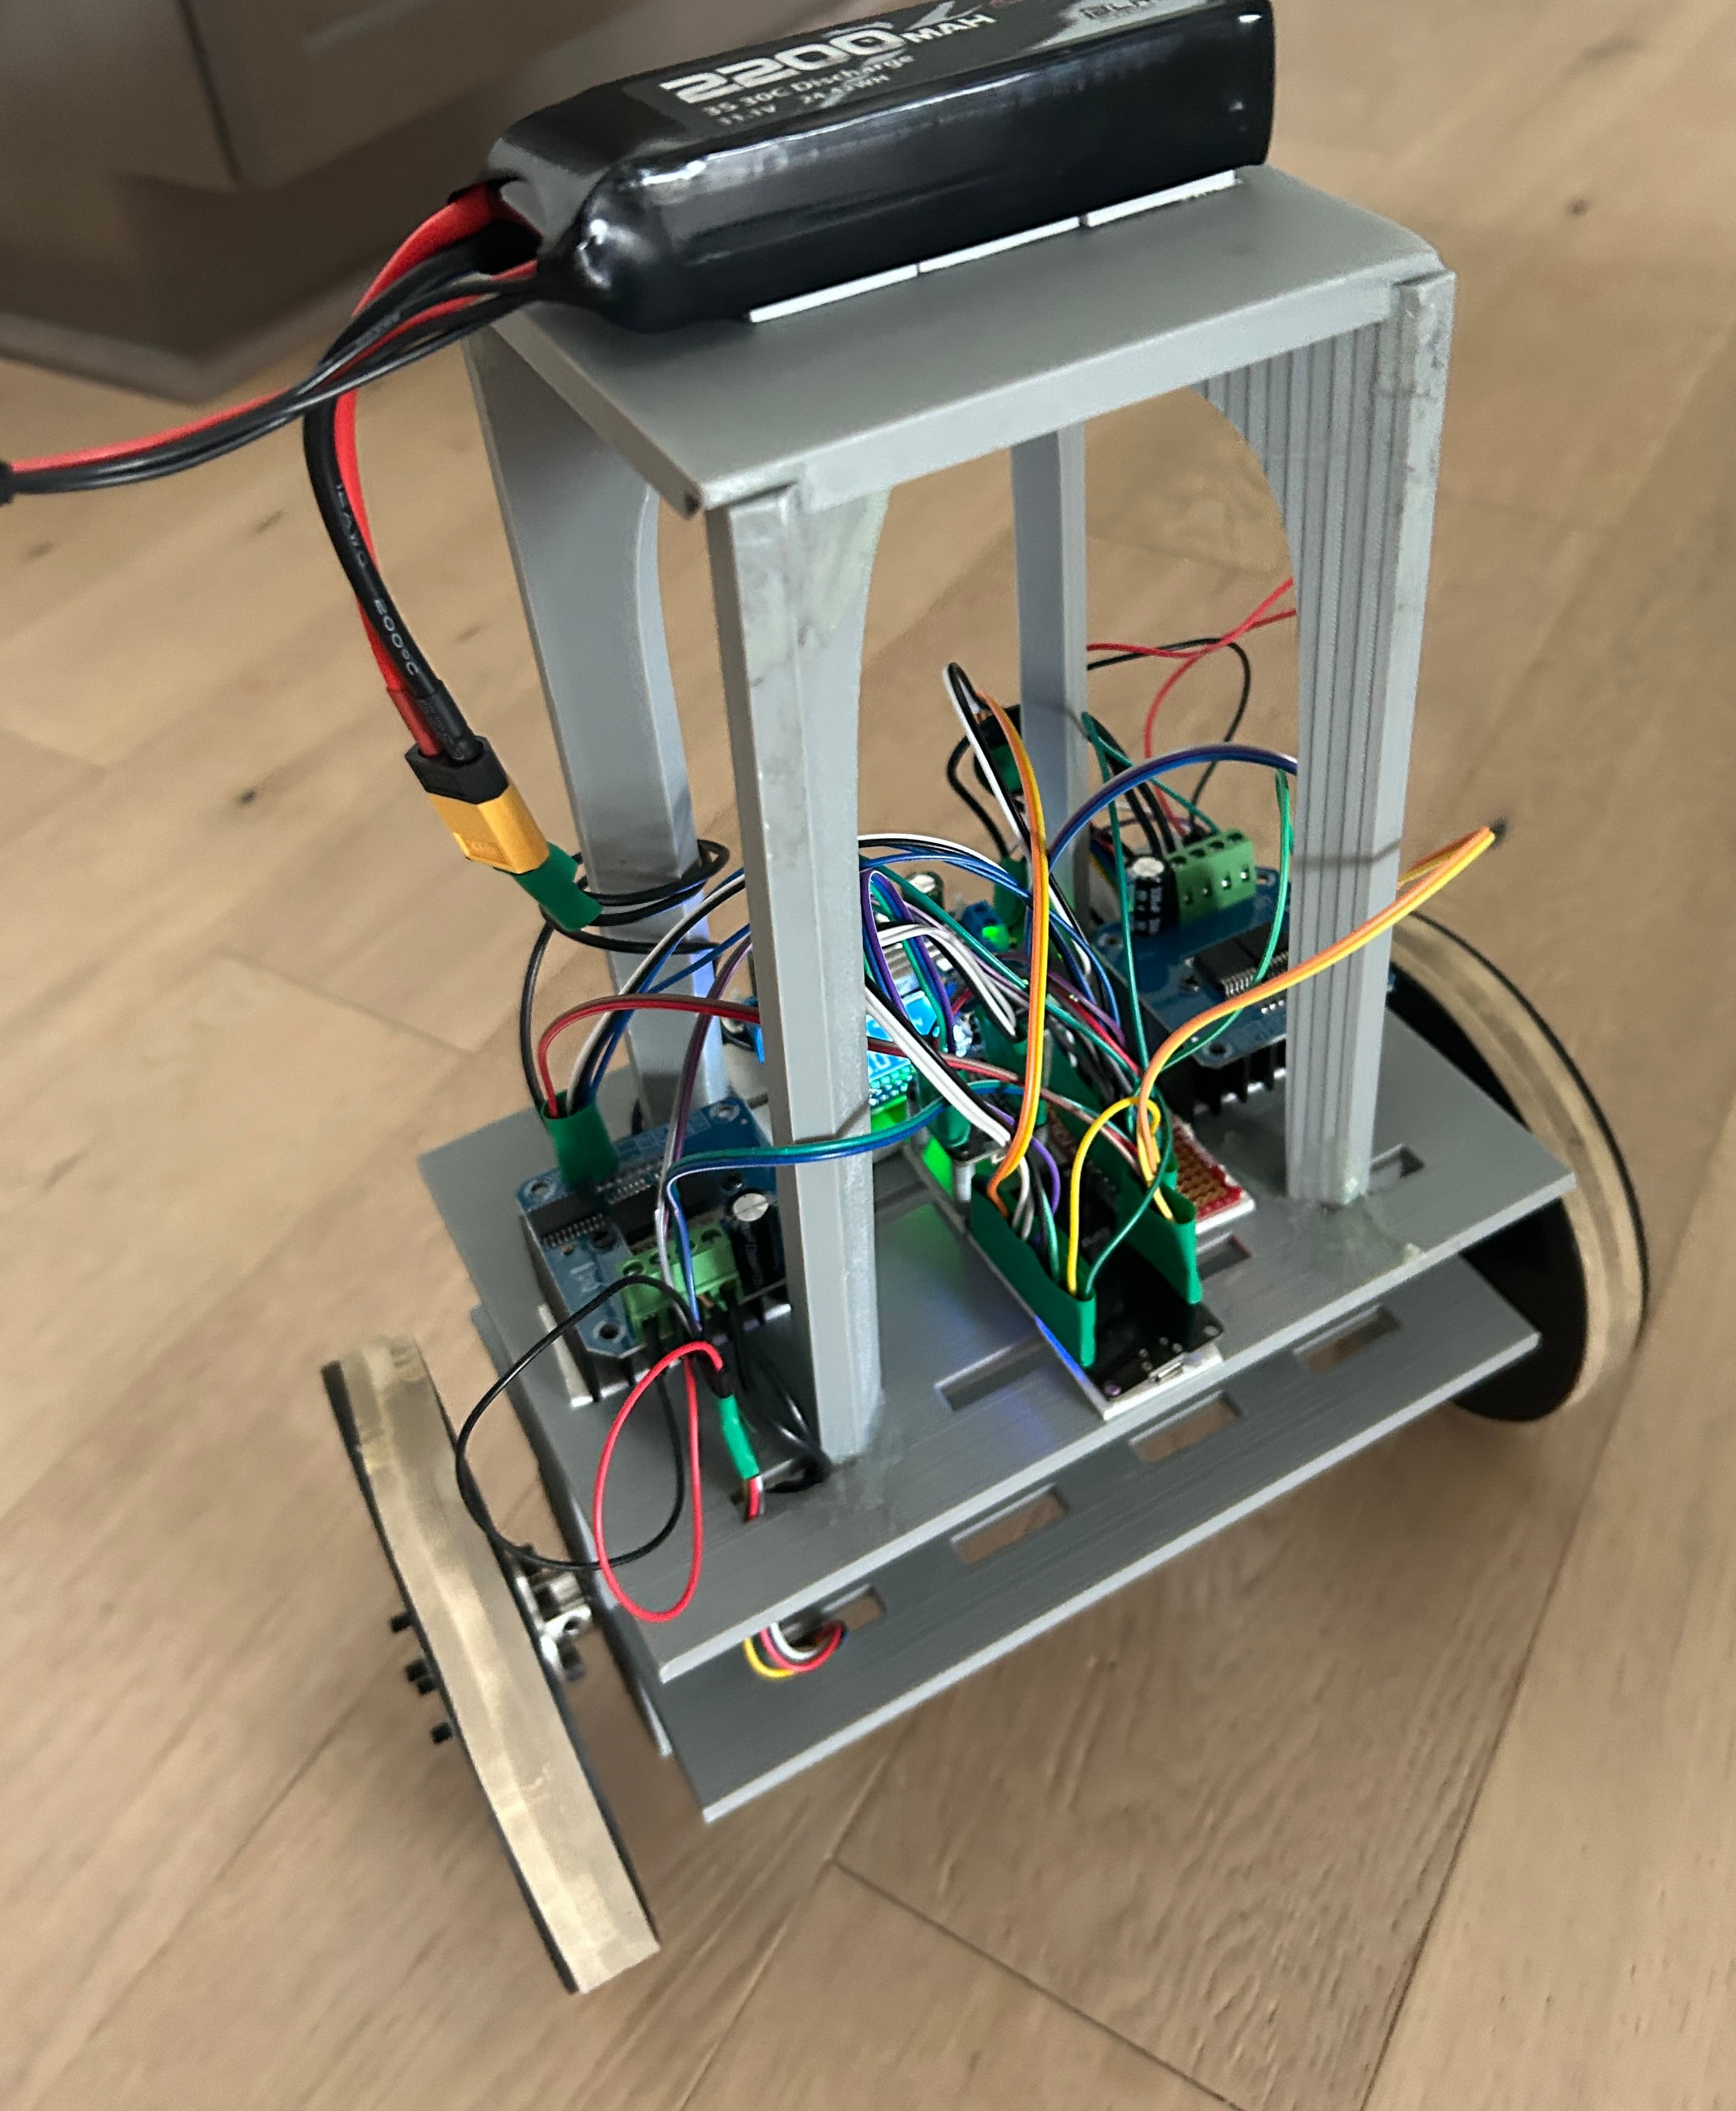
Two-wheeled inverted-pendulum robot: ESP32 firmware on FreeRTOS, an IMU over SPI, and PID balance control tuned live over Bluetooth.

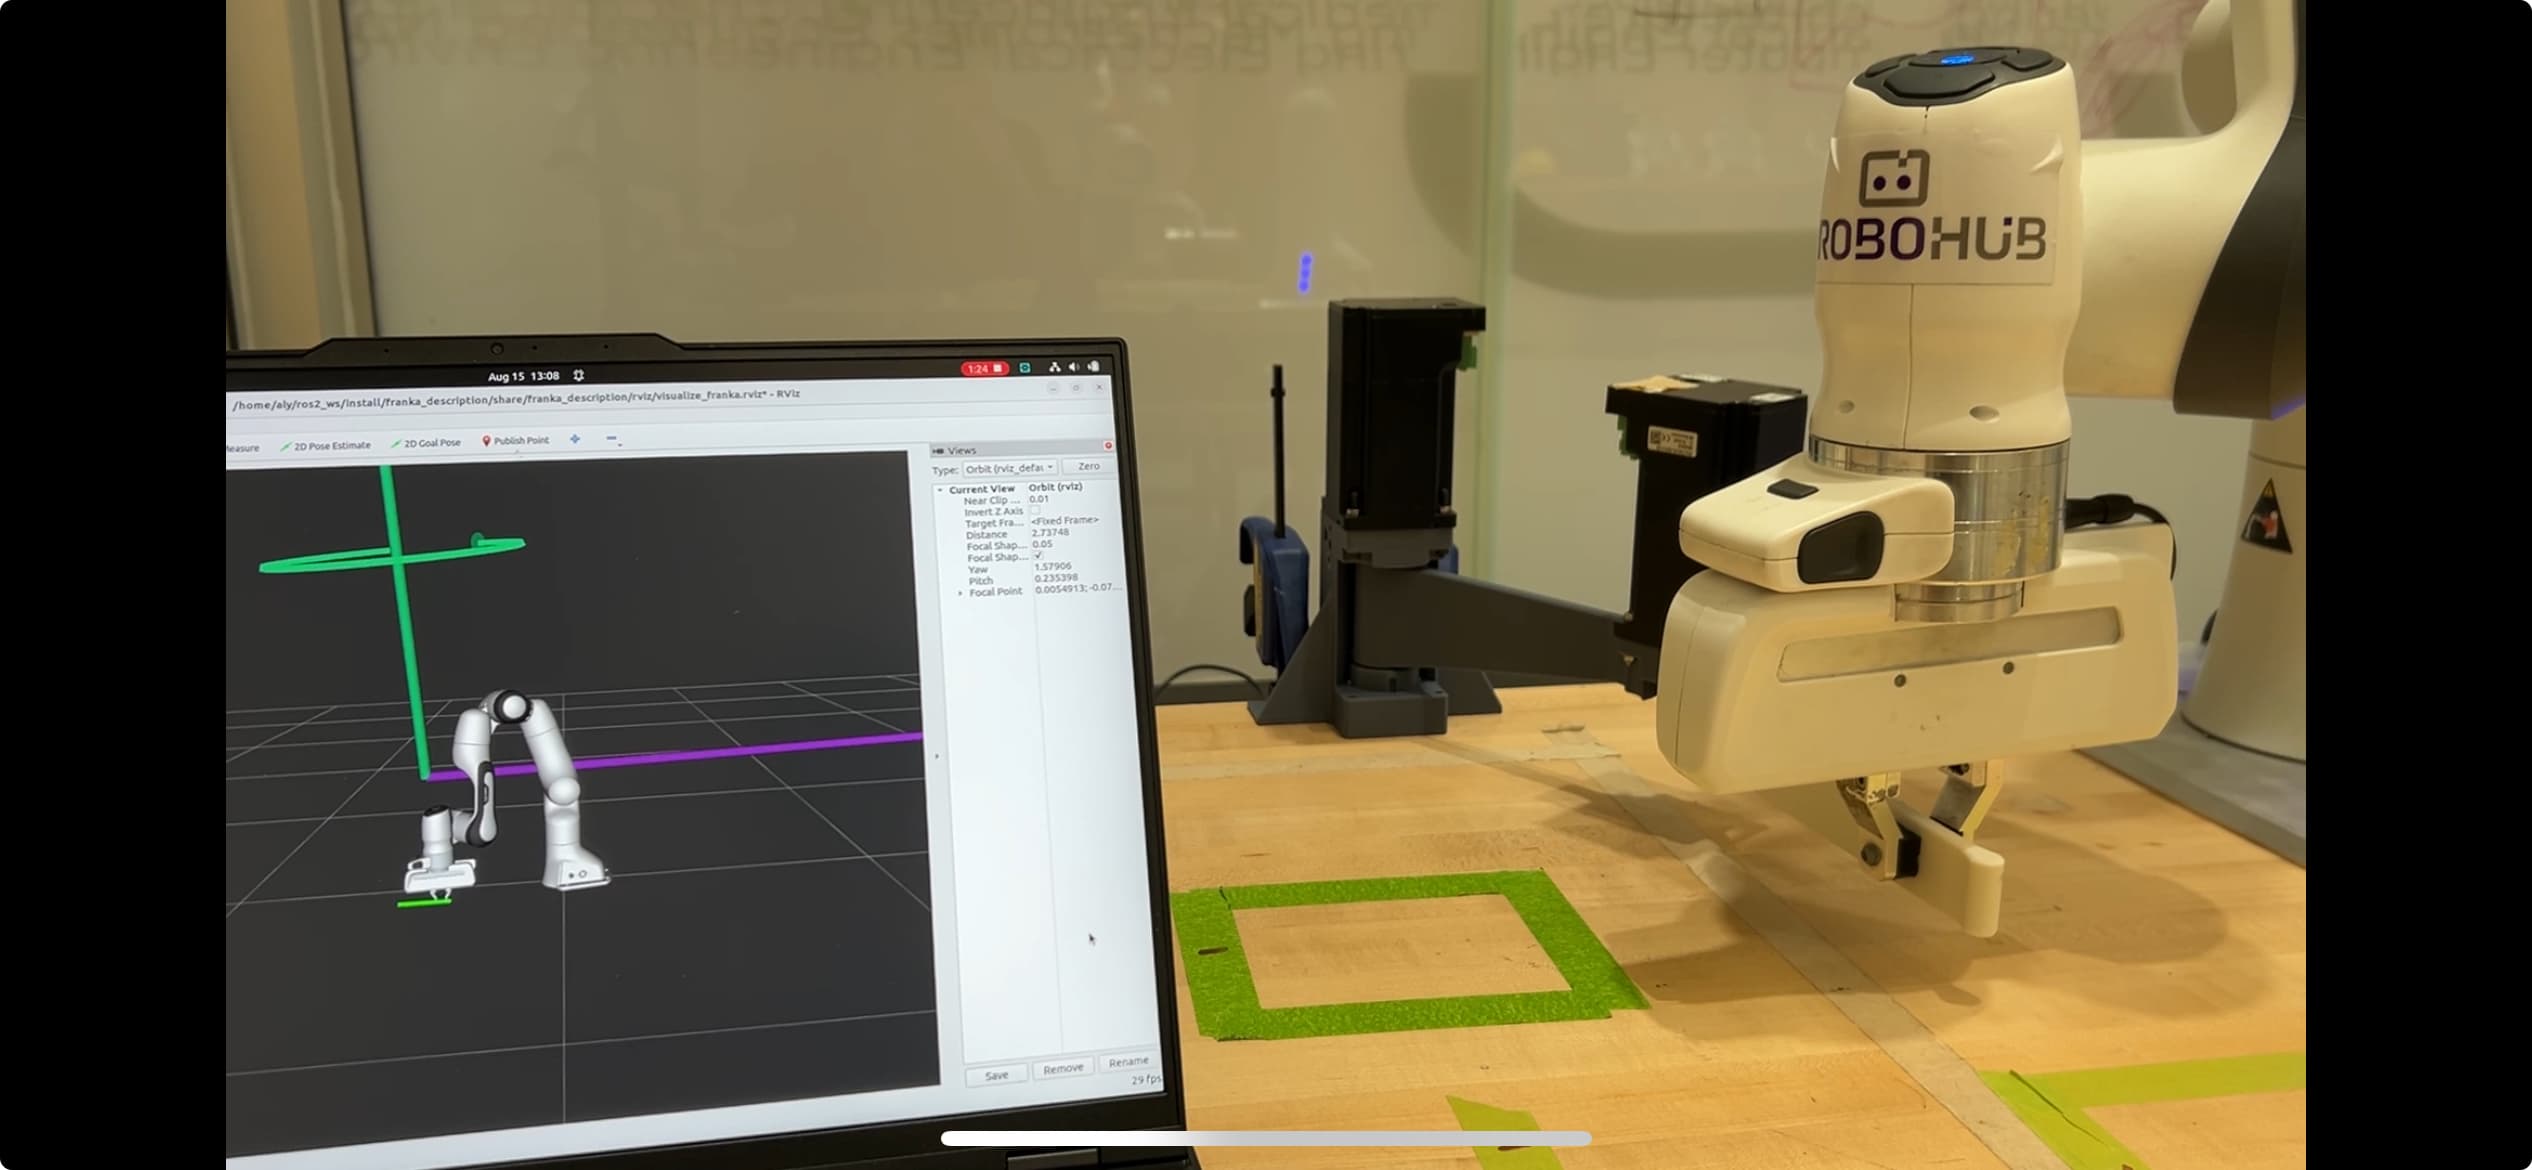
Factor-graph articulation estimation ported to ROS2 on a Franka Emika Panda, with a joint impedance controller that lets the robot safely explore unknown objects.

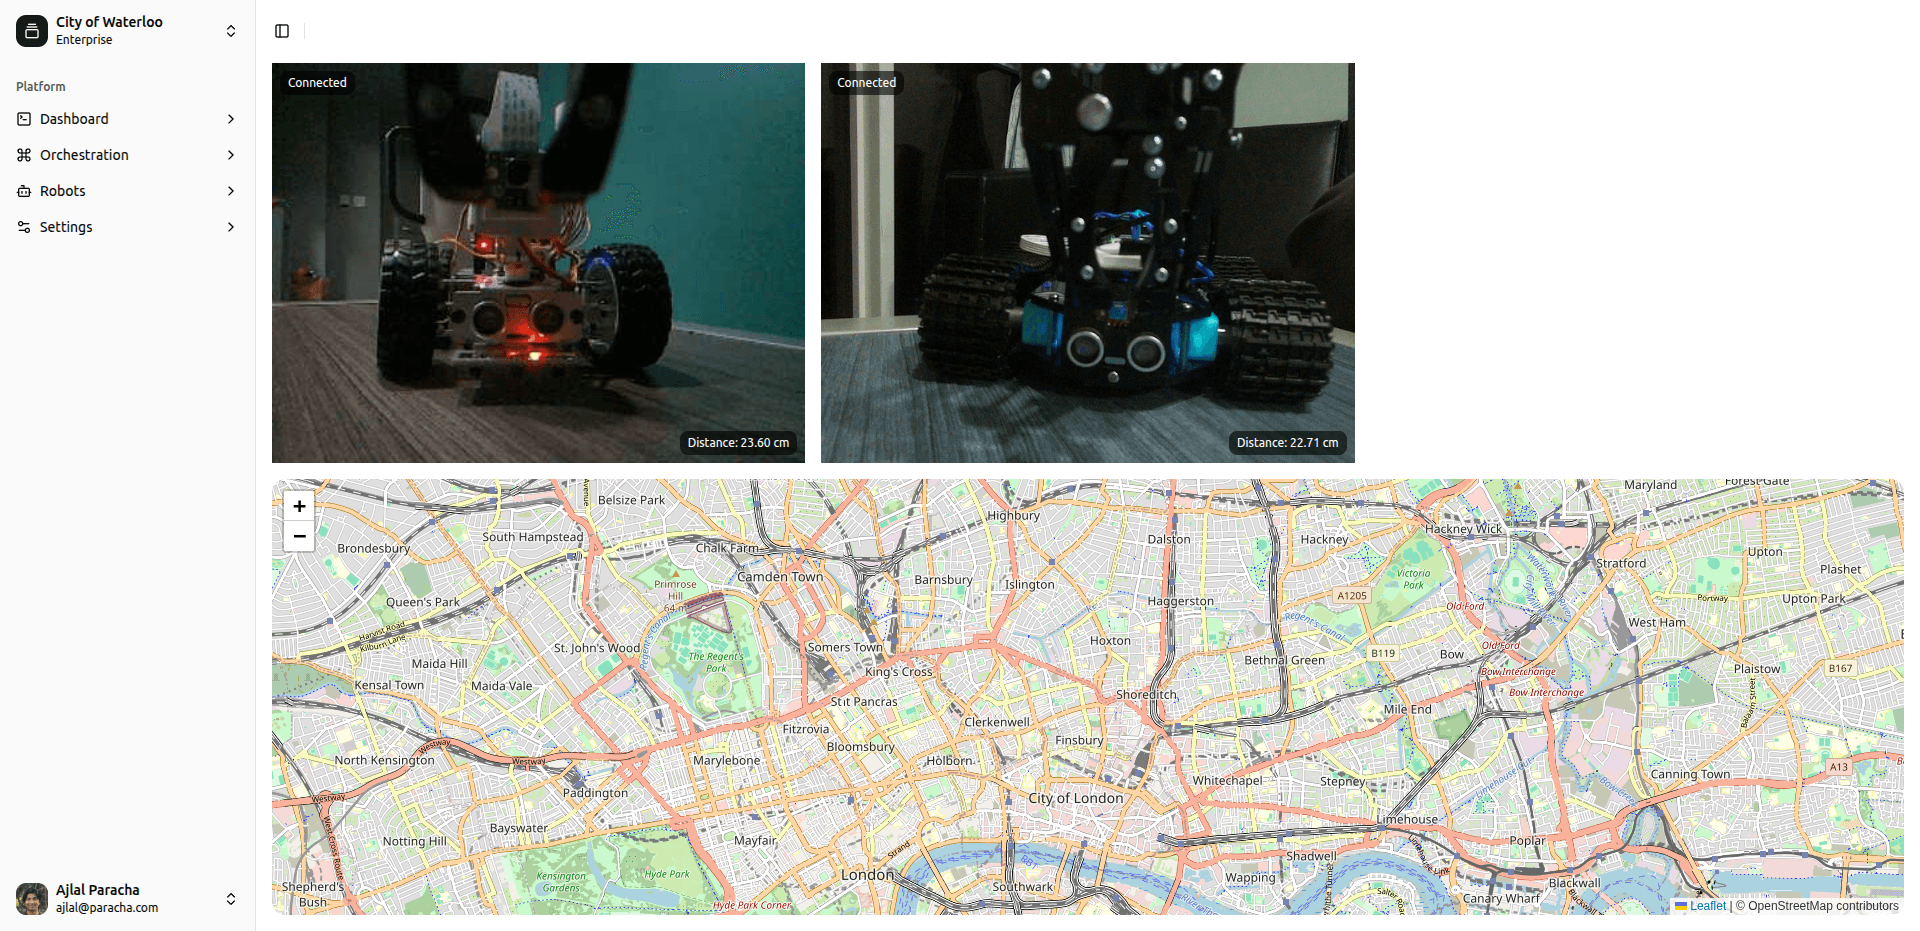
Hack the North 2025: control a whole fleet of robots from a single natural-language prompt, with a live dashboard of camera feeds and sensor data.

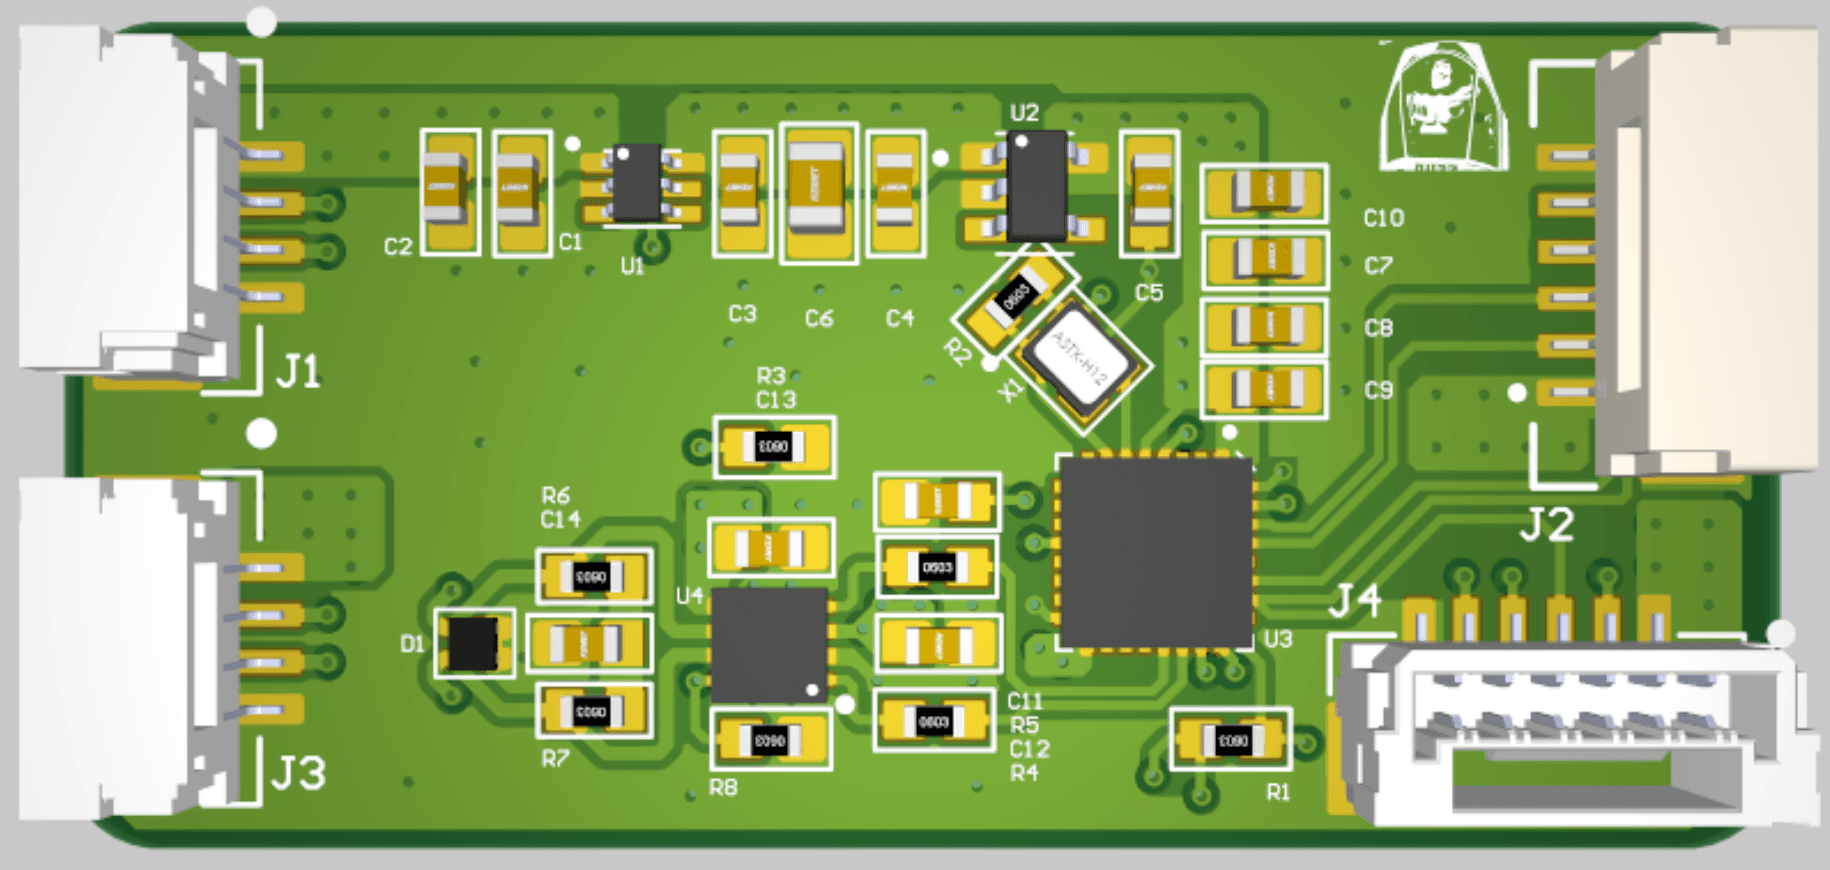
PCB layout for an STM32-based adapter that receives CAN messages, processes them in software, and forwards them over UART to peripherals.

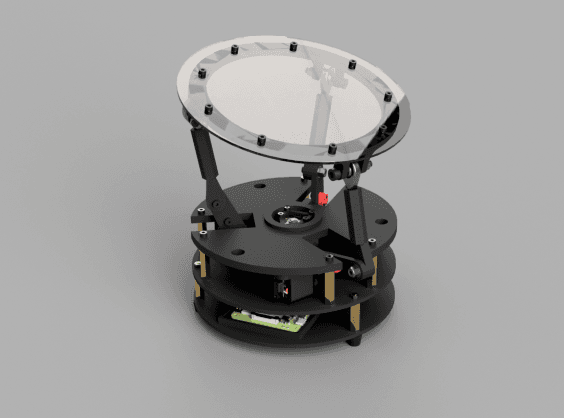
In progress: a 3-DOF platform that tracks a ball with OpenCV and tilts to steer it, combining PID control with inverse kinematics.

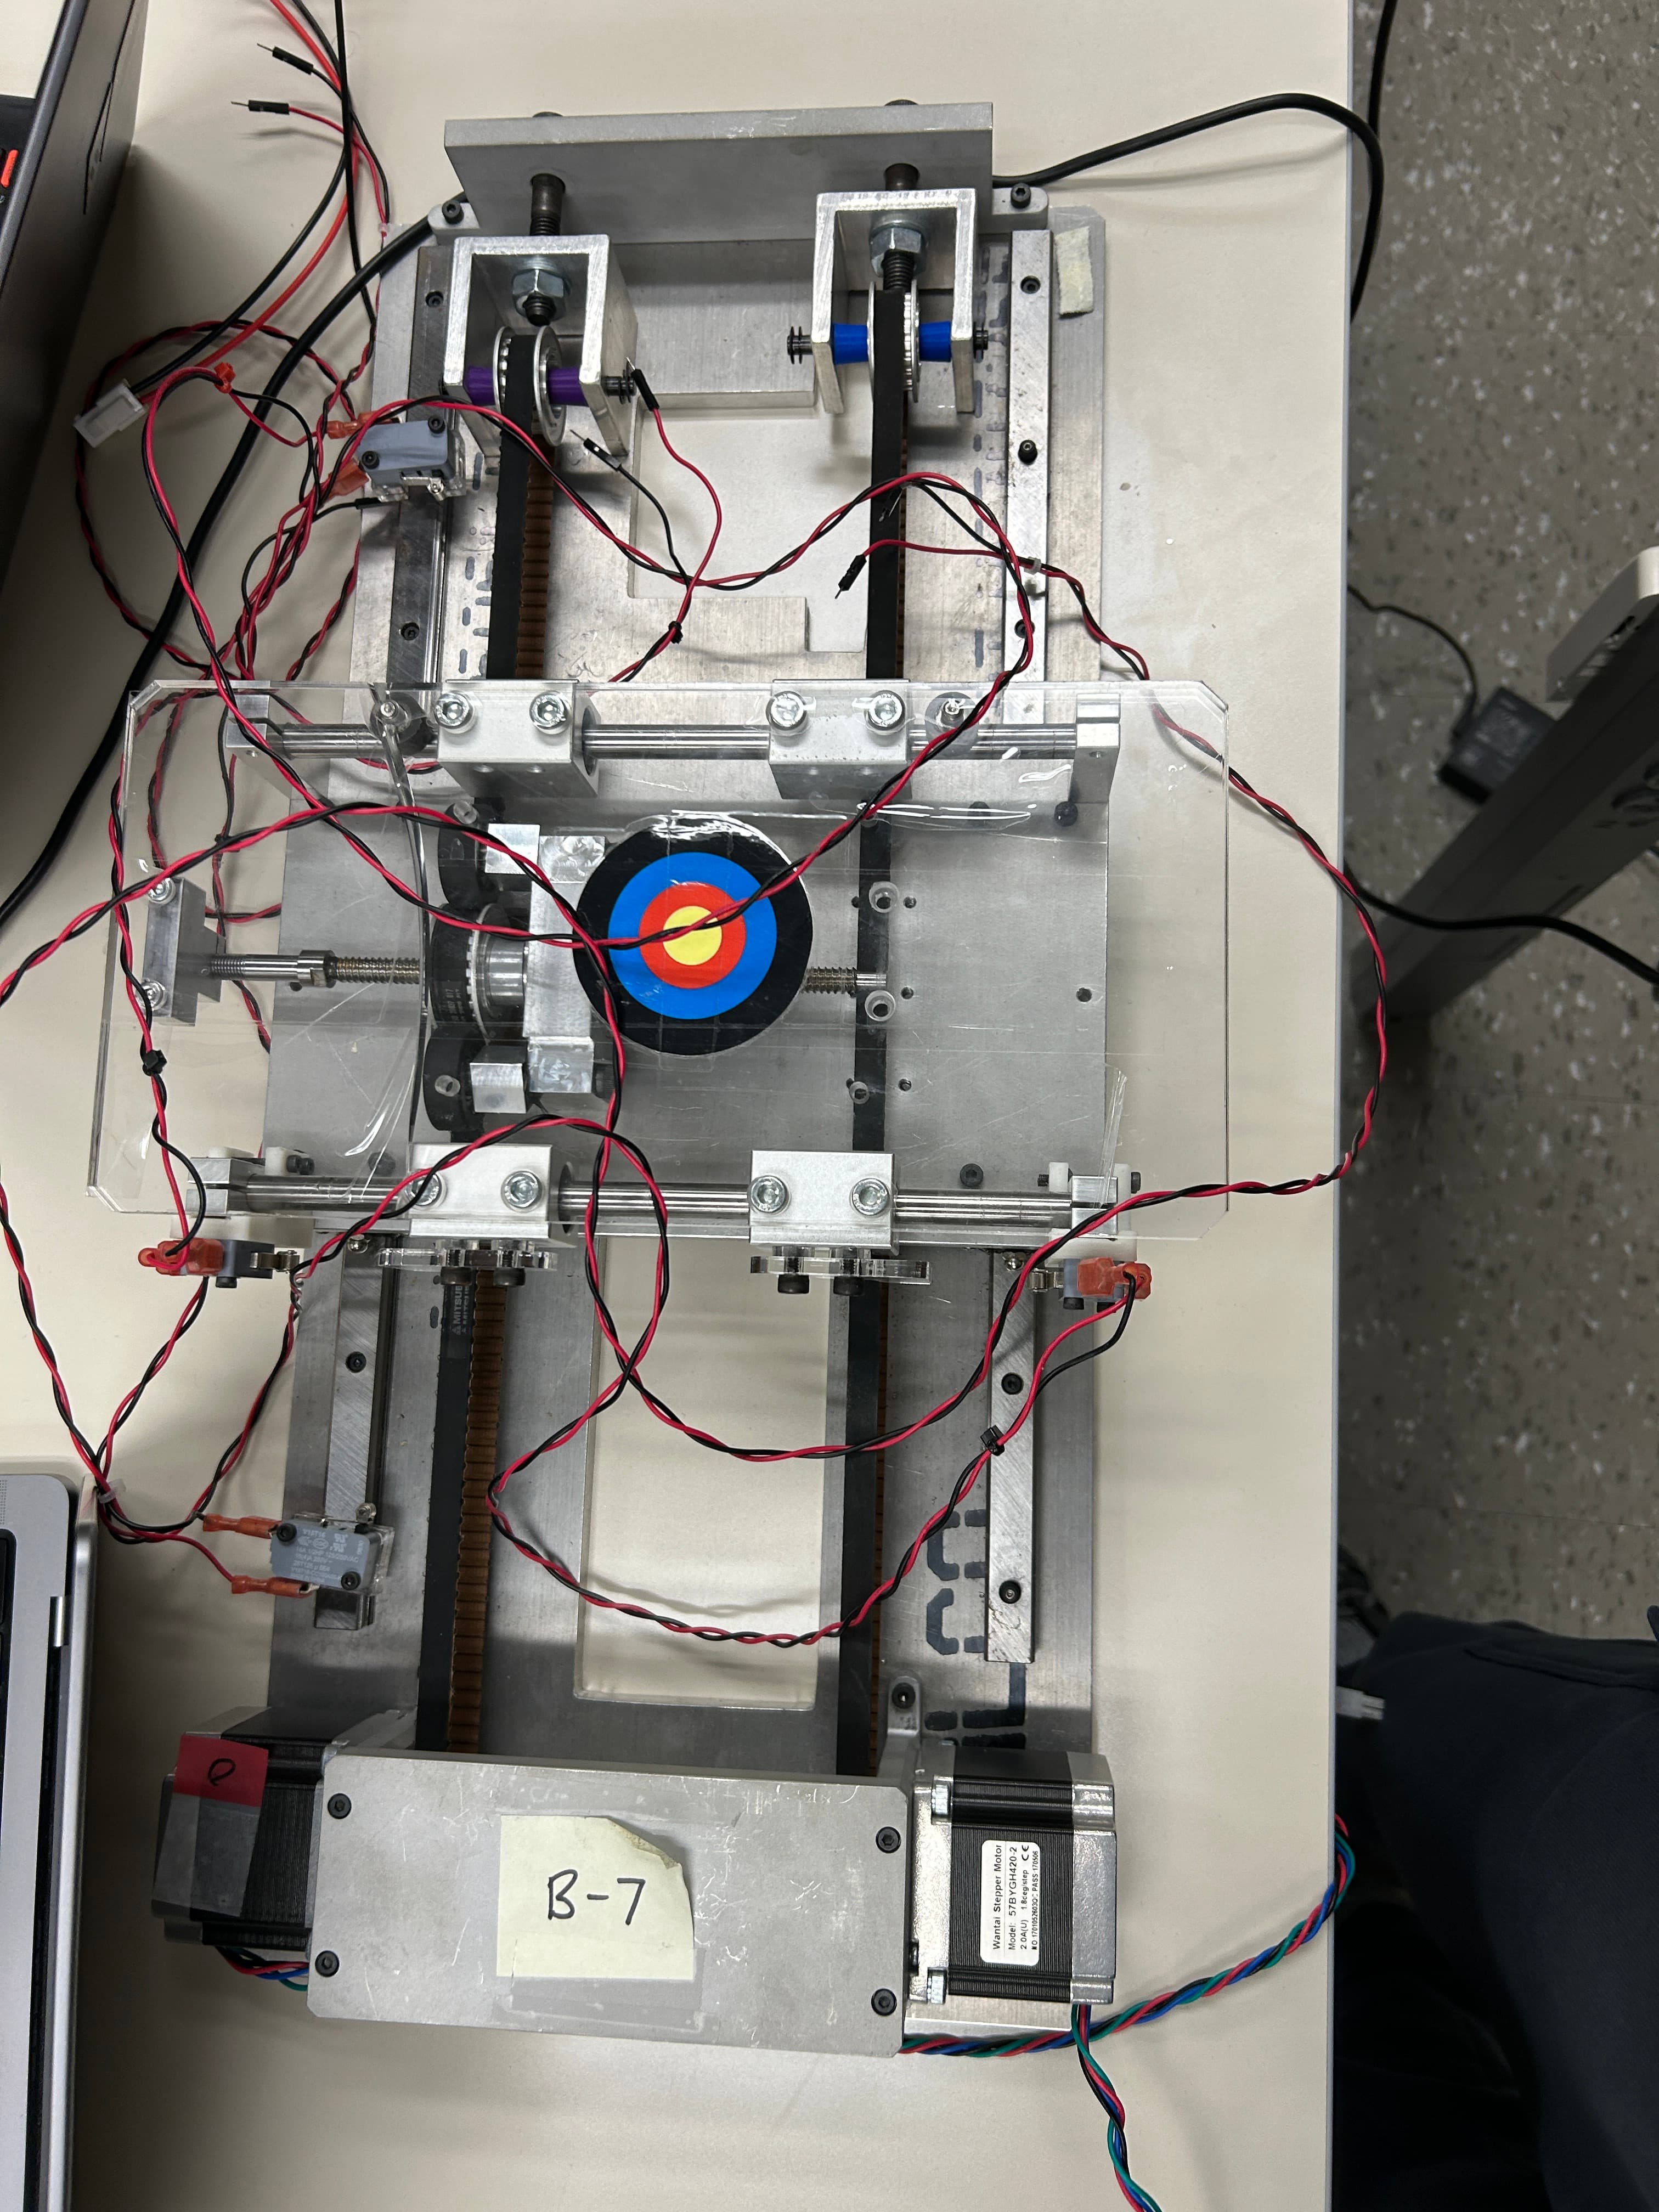
Bare-metal STM32 drivers for a 2-axis machine: ADC, interrupts, and GPIO for speed and direction control, with safety limit switches.